|
I co-founded MirroS, where we are building Physical RSI. I am a Ph.D. student at School of Computer Science, Peking University, where I am advised by Prof. Yizhou Wang and Prof. He Wang. I am also a collaborating scientist at NVIDIA Cosmos Lab, working with Dr. Ming-Yu Liu. My research centers on Embodied Agents. Previously, I focused on World Action Models, including large-scale projects such as Cosmos 3 and LDA-1B. My research objective is to endow embodied agents working in complex real-world environments with Generalizability, Adaptability, Agility and Dexterity. |
|
|
|
- NEW [2026/9] Six papers have been accepted to CoRL 2026!
- [2026/7] Our paper DAPL is selected as a 🏆 Best Paper Finalist at RSS 2026!
- [2025/7] Invited Talk at Sharpa and Prof. Chuan Wen's Lab at SJTU.
- [2024/12] Invited Talk at TechBeat.
|
|
| *: joint first author; † Project Lead; ✉ corresponding author(s) |
|
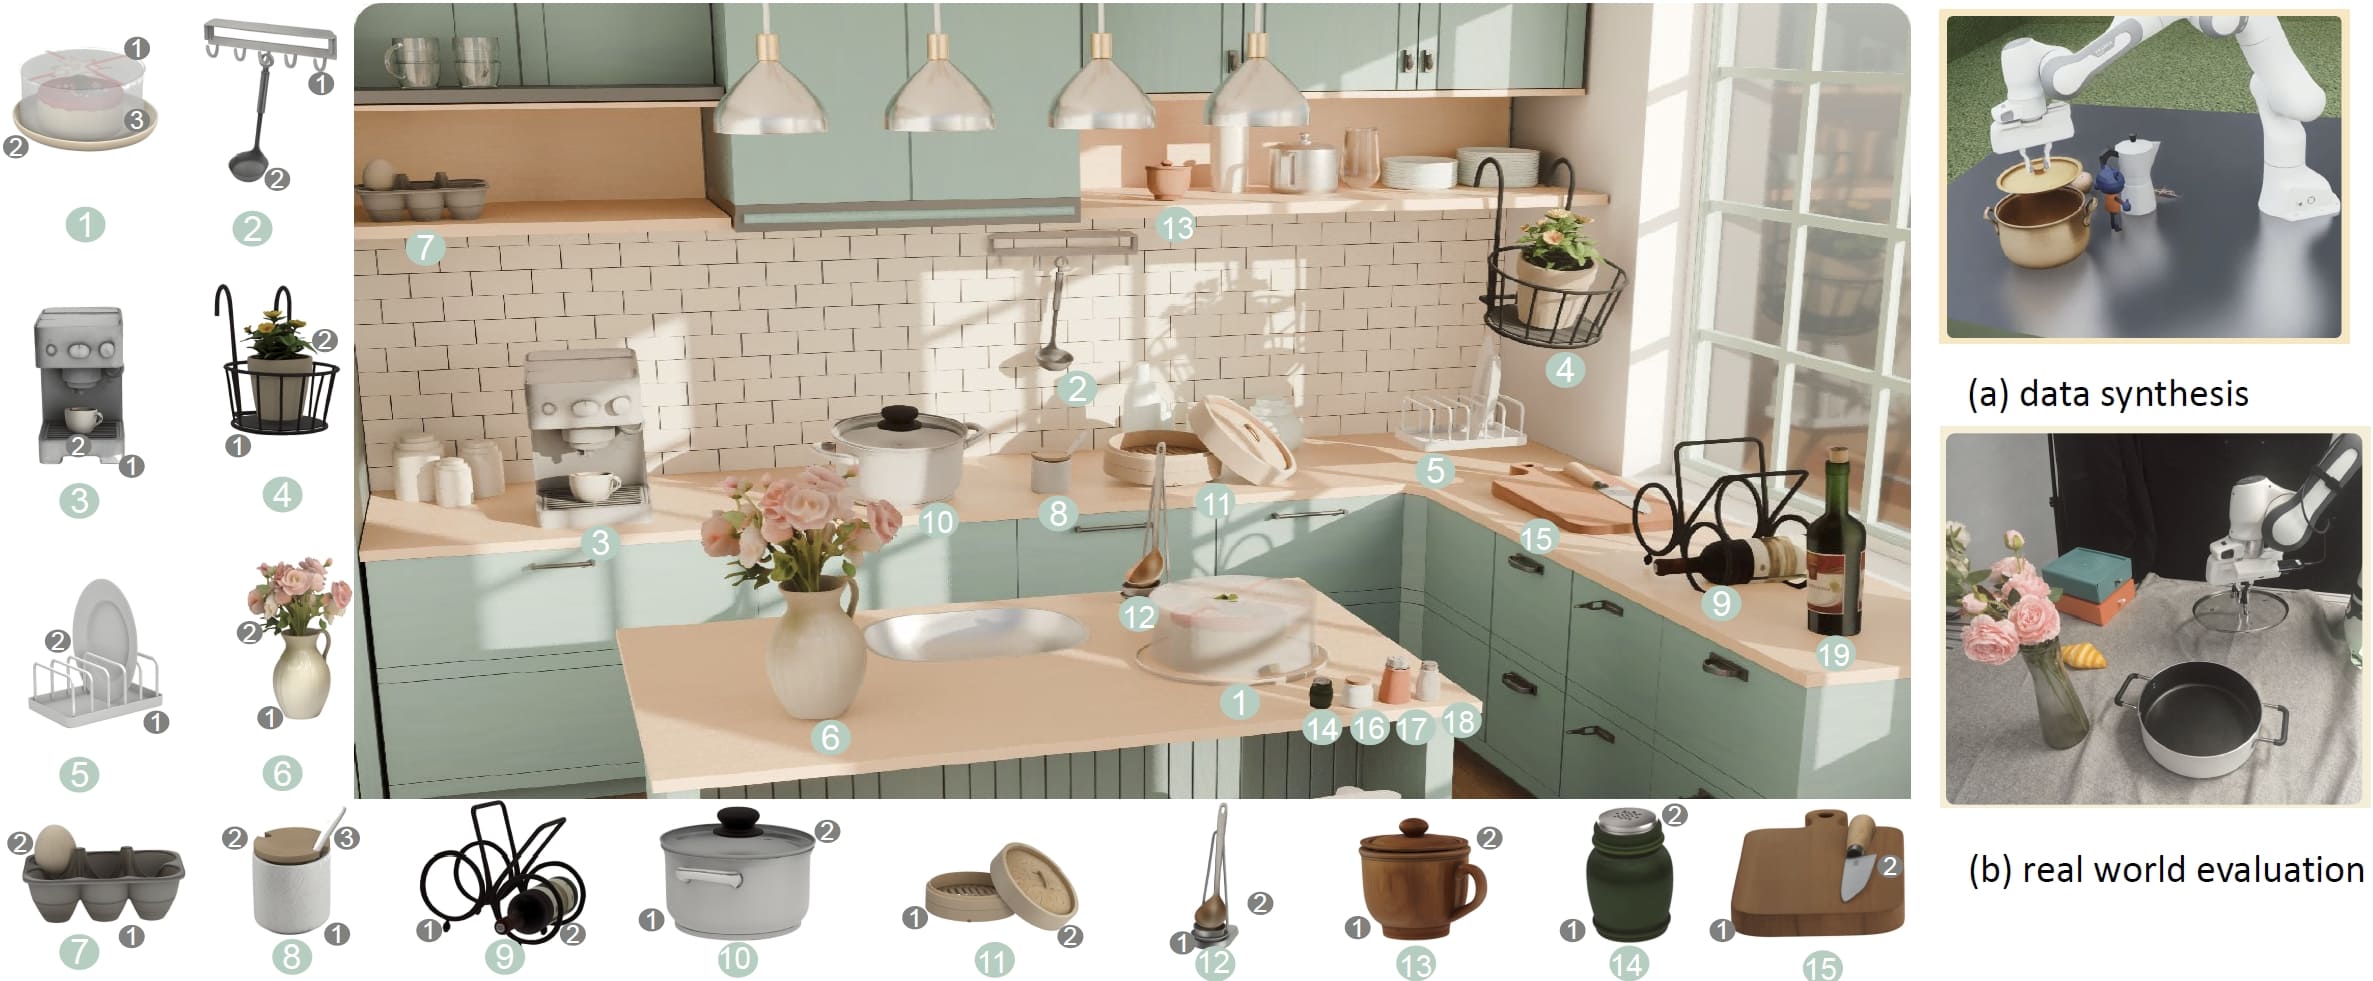
Long Xu*, Zhiqi Zhang*, Mi Yan*, Shengliang Deng, Chong Xia, Mingyu Dong, Jiayi Chen, Jiangran Lyu, Fei Gao, Zhizheng Zhang†, He Wang† Conference on Robot Learning (CoRL), 2026 arXiv / project page |
|
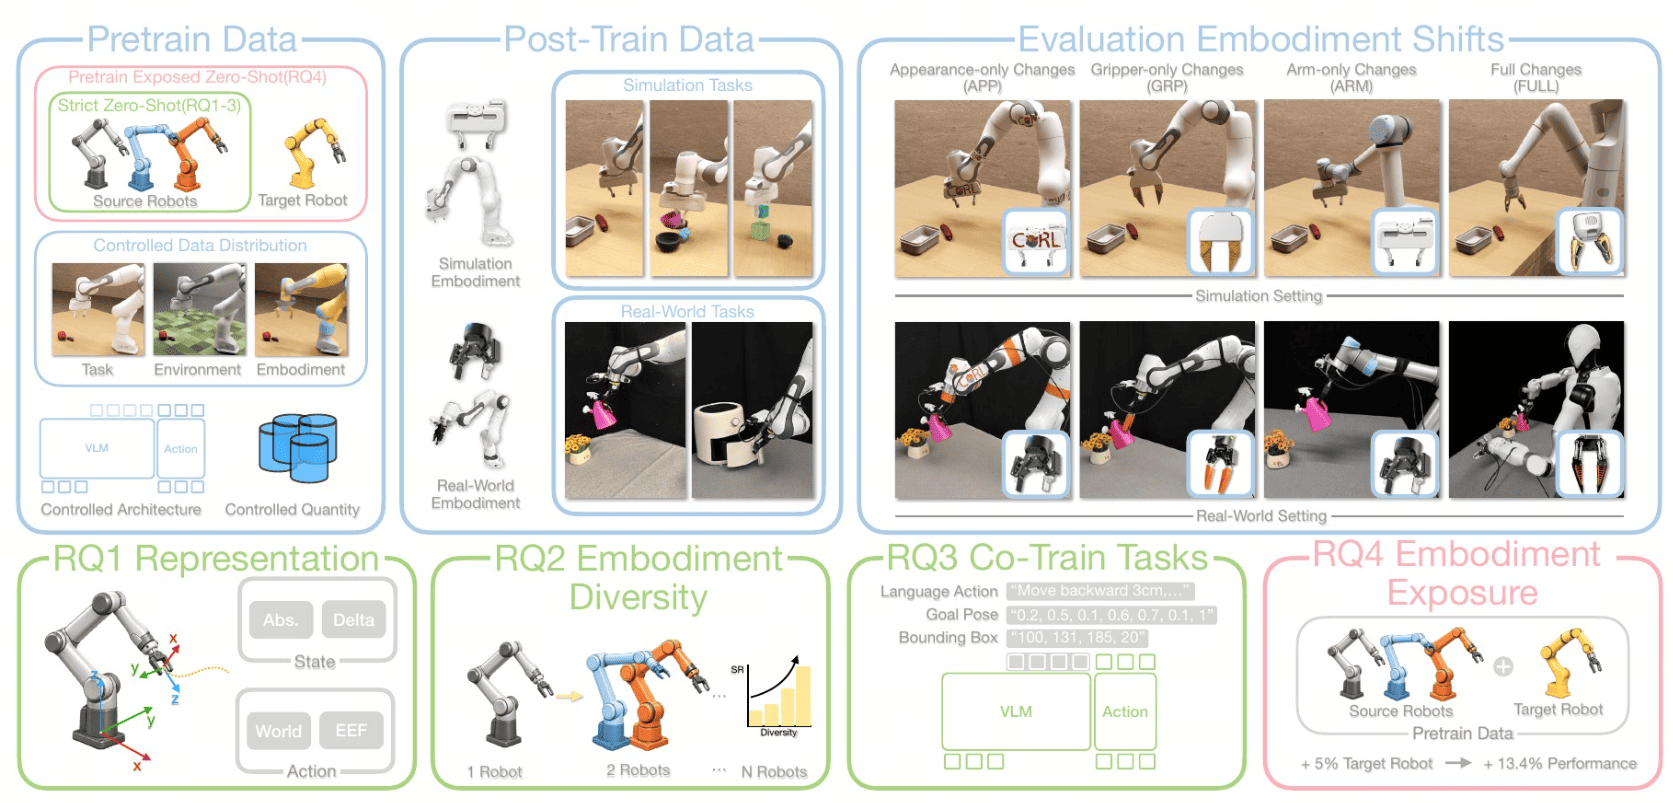
Mi Yan*, Wenhao Zhang*, Zhiqi Zhang*, Yu Peng*, Tangxinyu Wang*, Lingfei Zhai, Jiayi Su, Shengliang Deng, Lin Peng, Yaowei Liu, Yuxing Chen, Zhiyuan Wei, Jilong Wang, Jiayi Chen, Jiangran Lyu, Zhizheng Zhang†, He Wang† Conference on Robot Learning (CoRL), 2026 Spotlight arXiv |
|
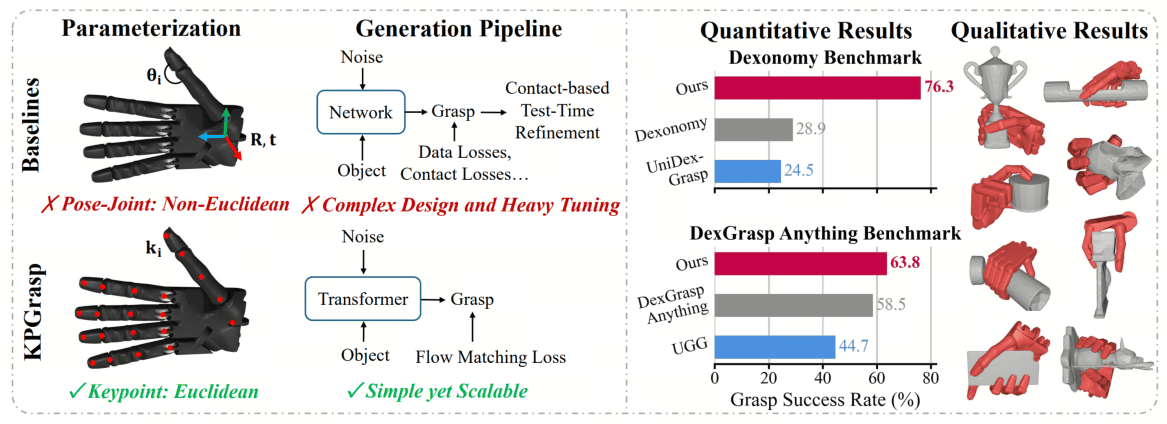
Yuansen Huang*, Jiayi Chen*, Haoran Liu, Yubin Ke, Bing Han, Jiangran Lyu, Mi Yan, Li Yi, He Wang† Conference on Robot Learning (CoRL), 2026 Spotlight arXiv / project page |
|
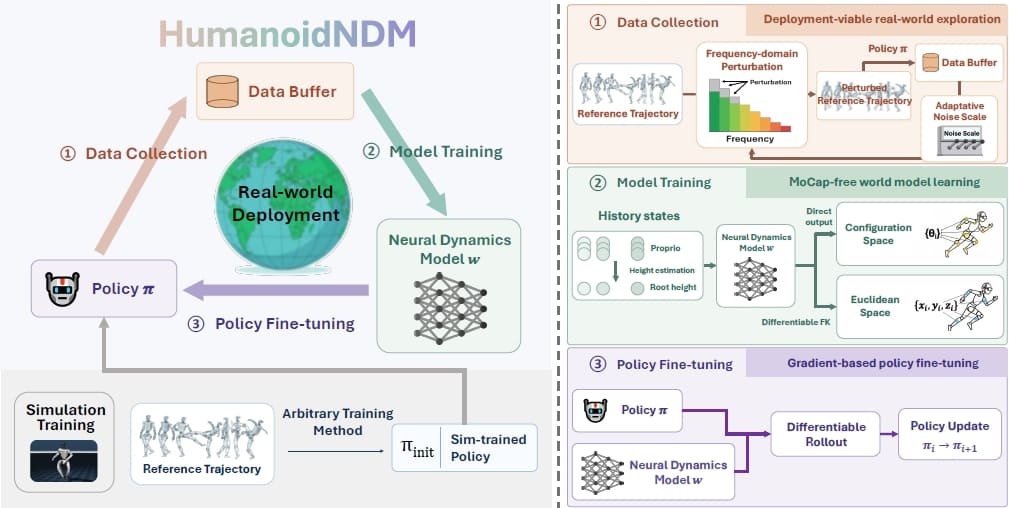
Chao Chen*, Zhenrong Wang*, Jilong Wang, Yusen Feng, Jiangran Lyu, Li Yi, He Wang† Conference on Robot Learning (CoRL), 2026 |
|
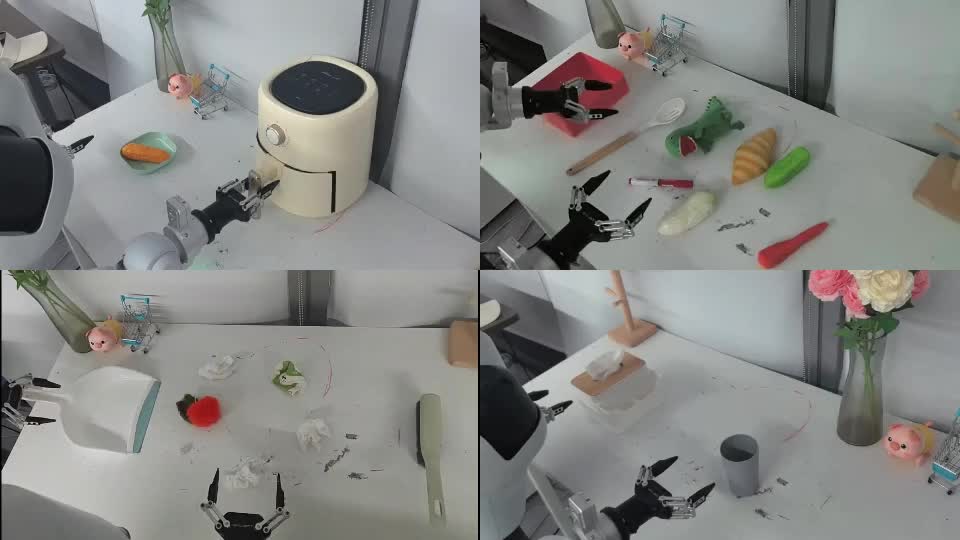
Kai Liu*, Jiangran Lyu*, Tingyu Deng, Yixin Zheng, Jingtian Wan, Wenbo Cui, Mi Yan, Yizhou Zhou, Haoran Li, Dongbin Zhao, Zhizheng Zhang, He Wang arXiv preprint, 2026 arXiv / project page |
|
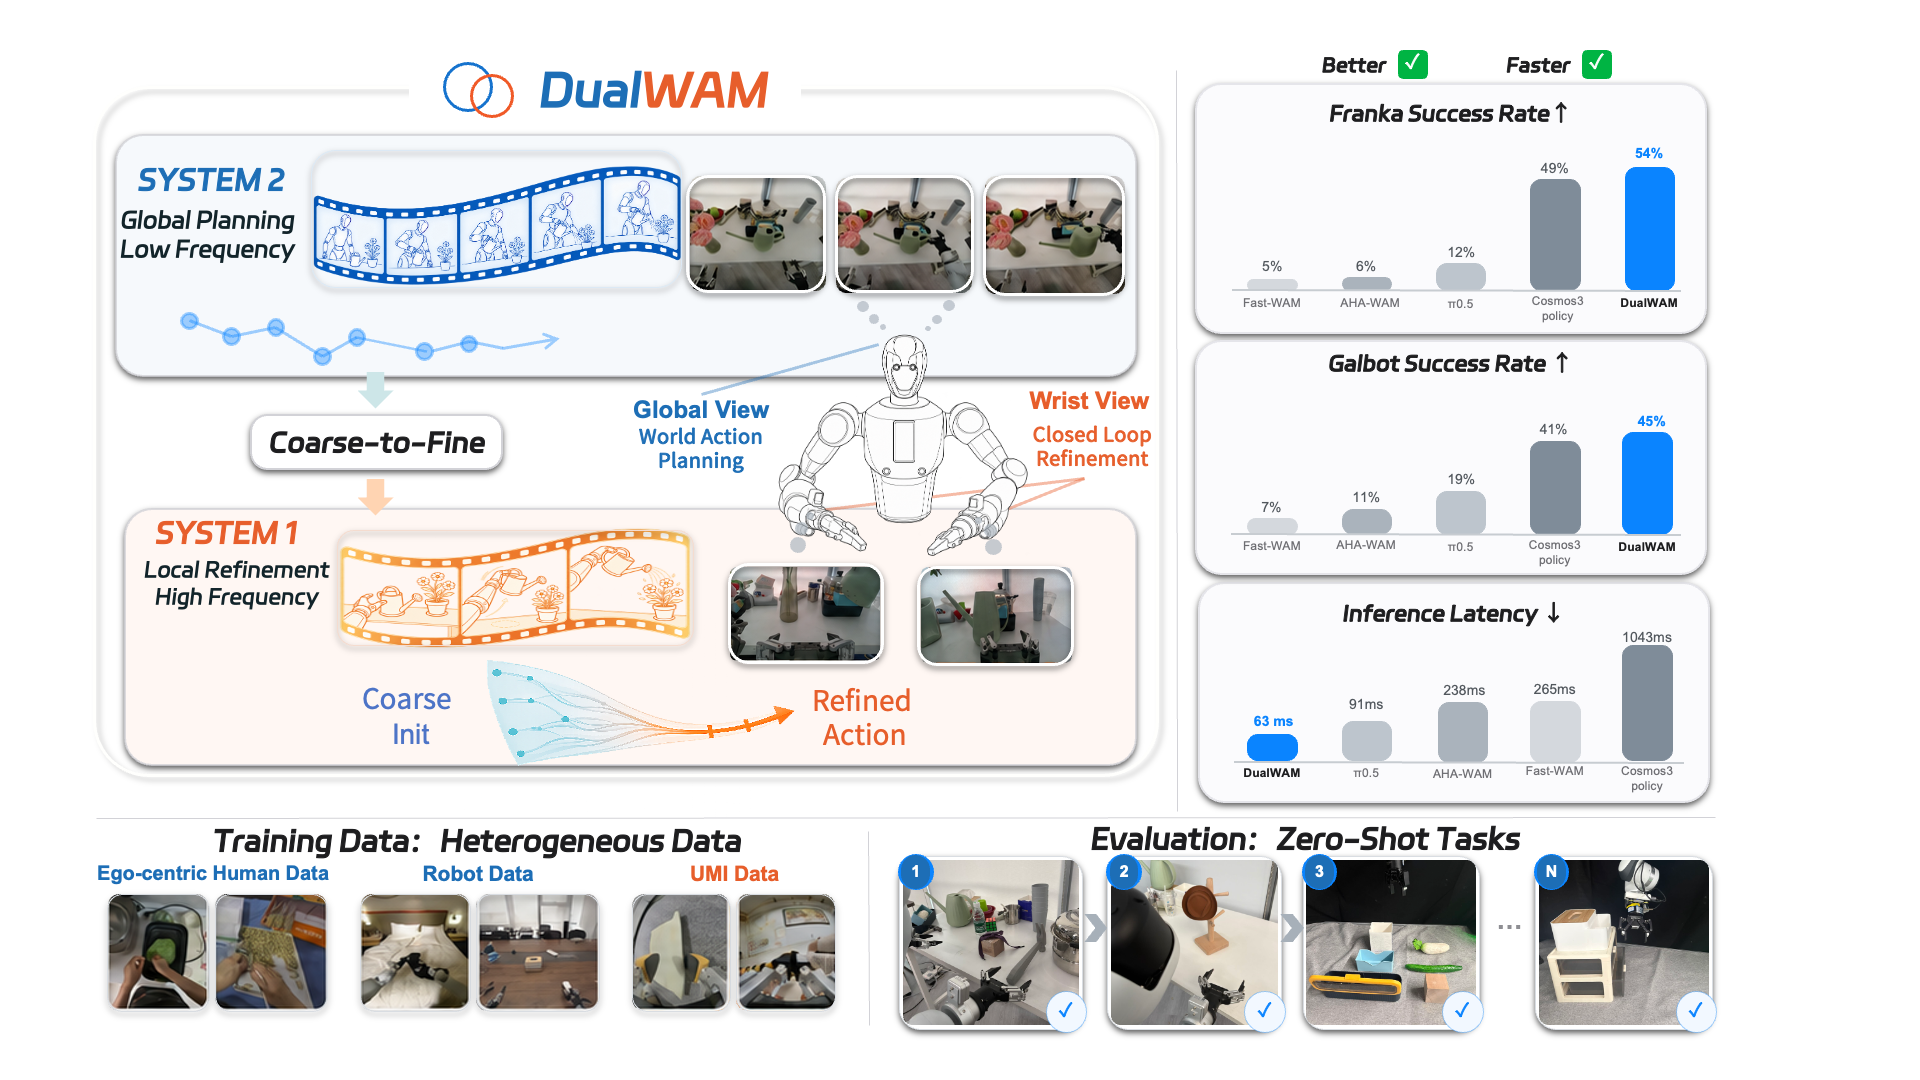
Yixin Zheng*, Jiangran Lyu*, Yuntian Deng, Kai Liu, Yizhou Zhou, Yizhou Wang, Xiaoguang Zhao, He Wang, Zhizheng Zhang arXiv preprint, 2026 arXiv / project page |
|
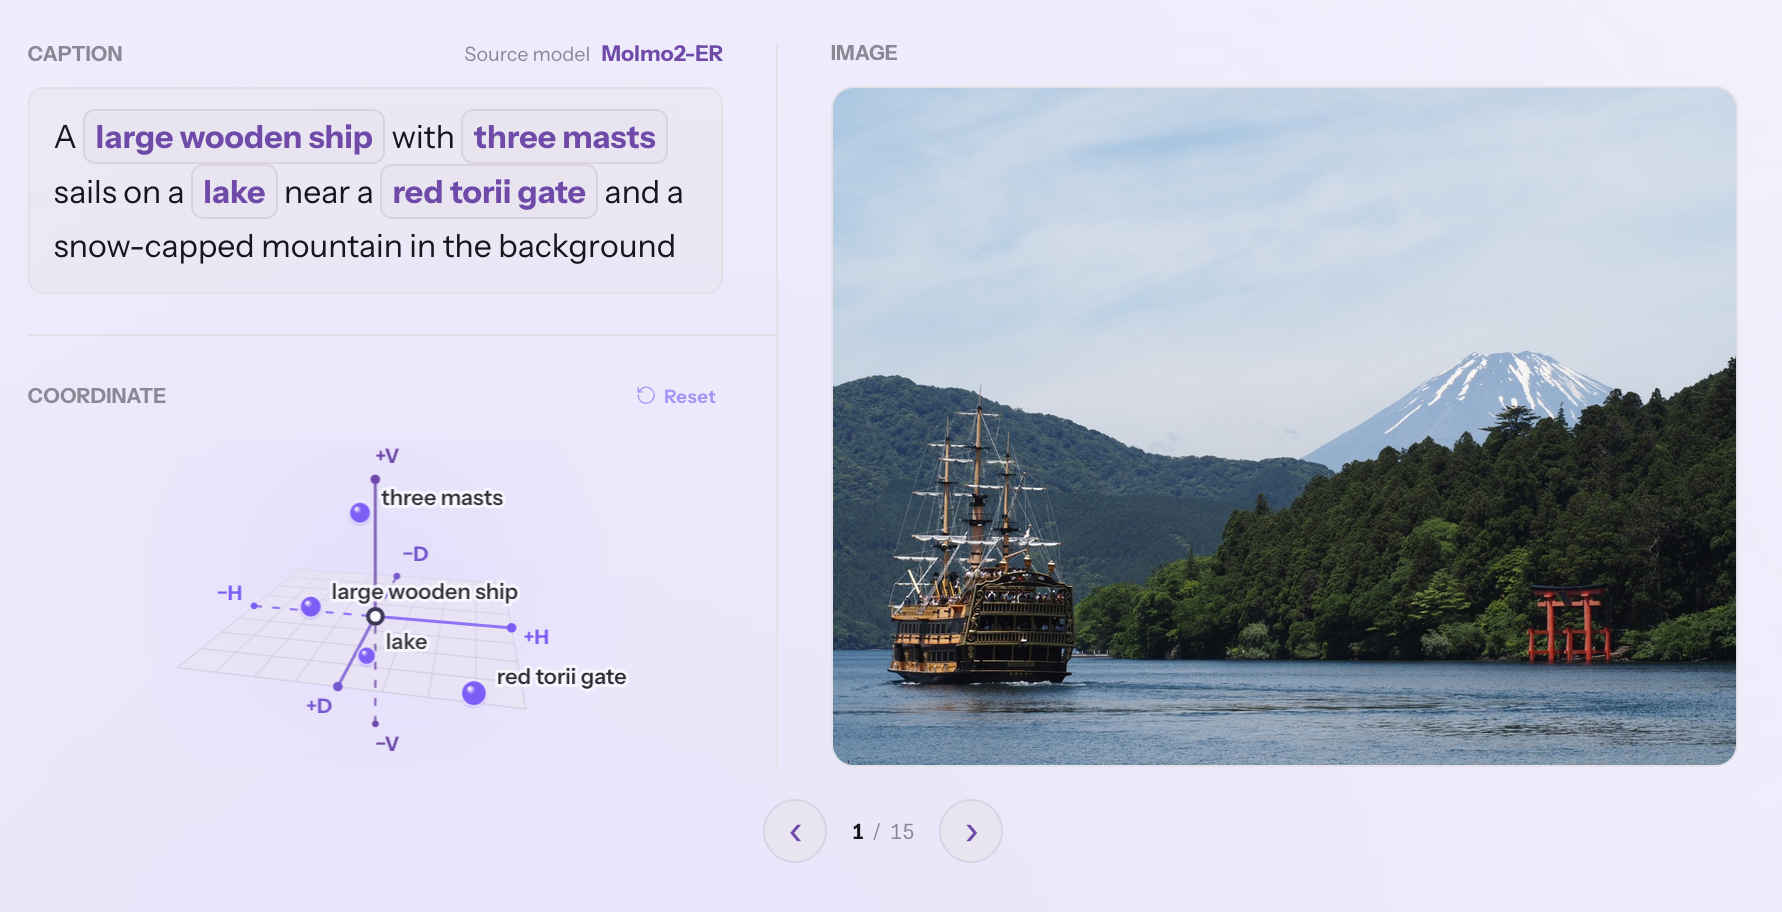
MirroS Team MirroS Technical Report, 2026 arXiv / project page |
|
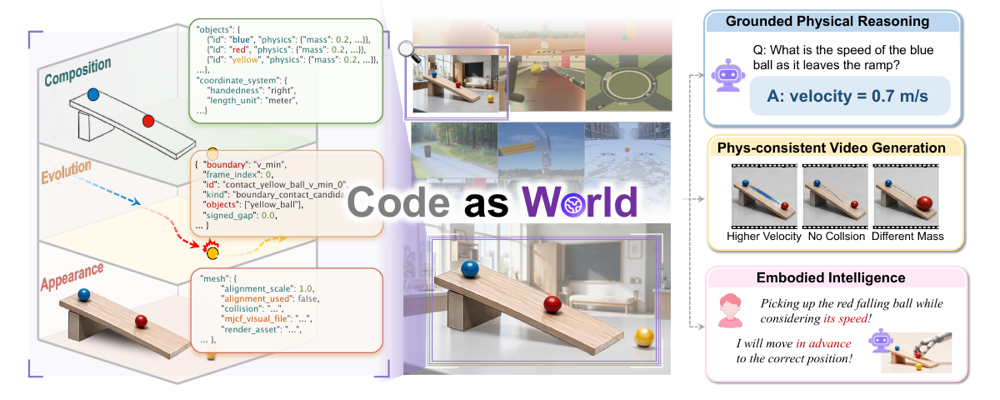
MirroS Team MirroS Technical Report, 2026 paper / project page / code / blog Code-as-World represents physical worlds as executable code and uses an agentic discovery loop to recover verifiable world representations from multimodal observations. |
|
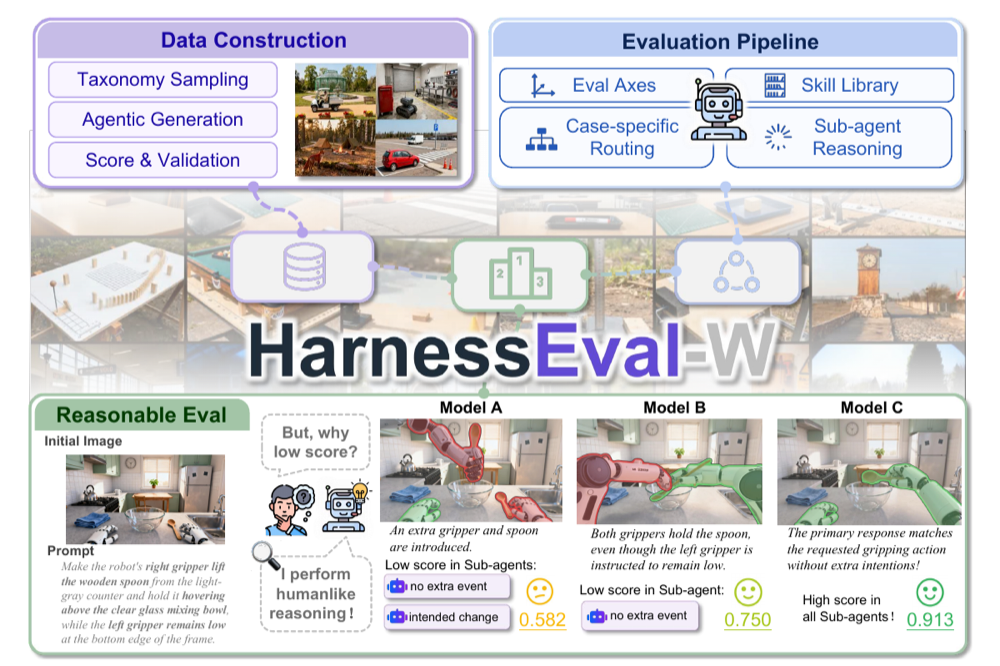
MirroS Team MirroS Technical Report, 2026 arXiv / project page / code / blog HarnessEval-W introduces an agentified evaluation pipeline that produces transparent evidence trees for world-model benchmarking. |
|
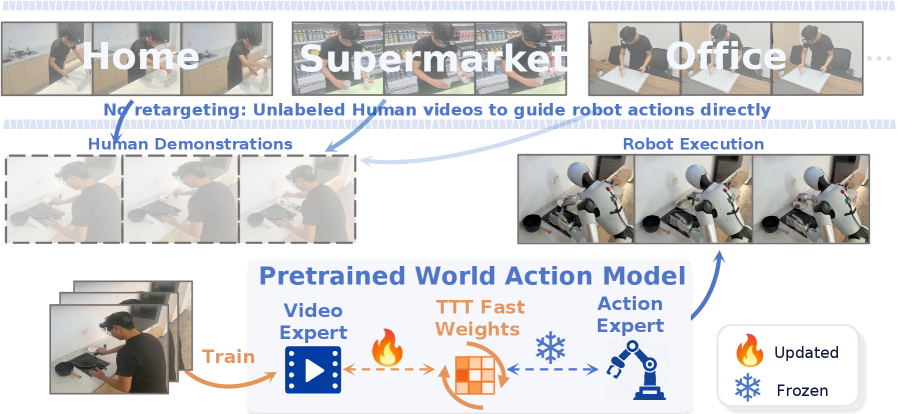
Yusen Feng*, Bingchen Han*, Jiangran Lyu*,†, Kai Liu, Yixin Zheng, Yuxuan Wan, Weiheng Liu, Sun Han, Ruiqin Li, Yulong Zhang, Fangfu Liu, Xuesong Shi, Libin Liu✉, Yizhou Wang✉, Zhizheng Zhang✉, He Wang✉ Conference on Robot Learning (CoRL), 2026 arXiv / project page / code |
|
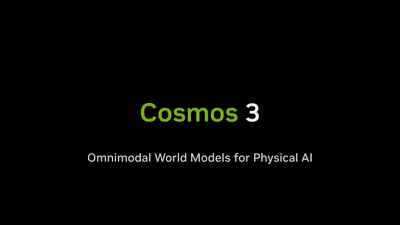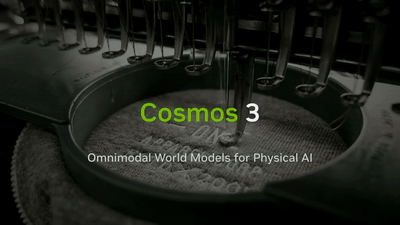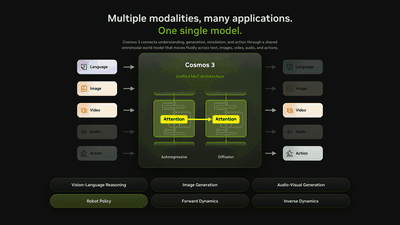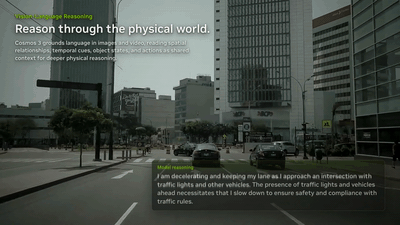
NVIDIA Cosmos Team (Contributor on action generation) Technical Report, 2026 paper / project page / code / models |
|
Yixin Zheng*, Jiangran Lyu*,†, Yifan Zhang, Jiayi Chen, Mi Yan, Yuntian Deng, Xuesong Shi, Xiaoguang Zhao, Yizhou Wang, Zhizheng Zhang✉, He Wang✉ Robotics: Science and Systems (RSS), 2026 🏆 Best Paper Finalist arXiv / project page / code By leveraging dynamics-aware policy learning, our approach enables robots to exploit environmental contacts and object interactions to accomplish complex manipulation. |
|
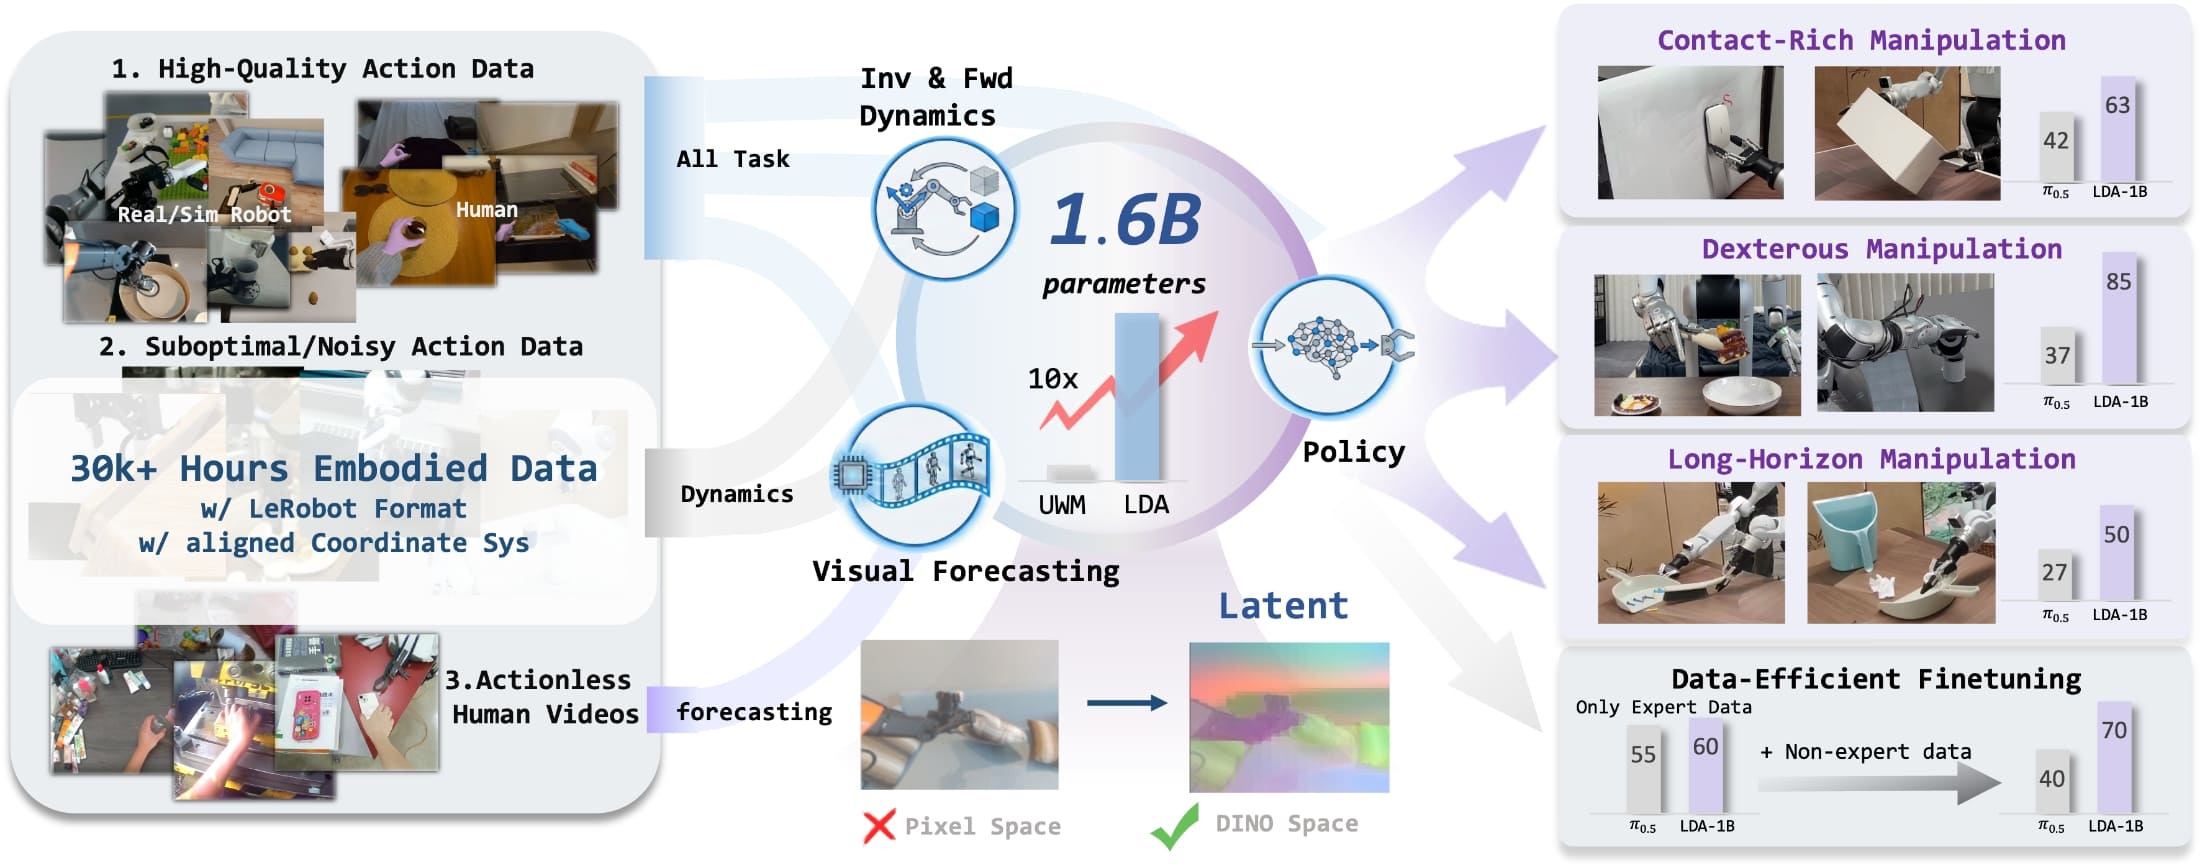
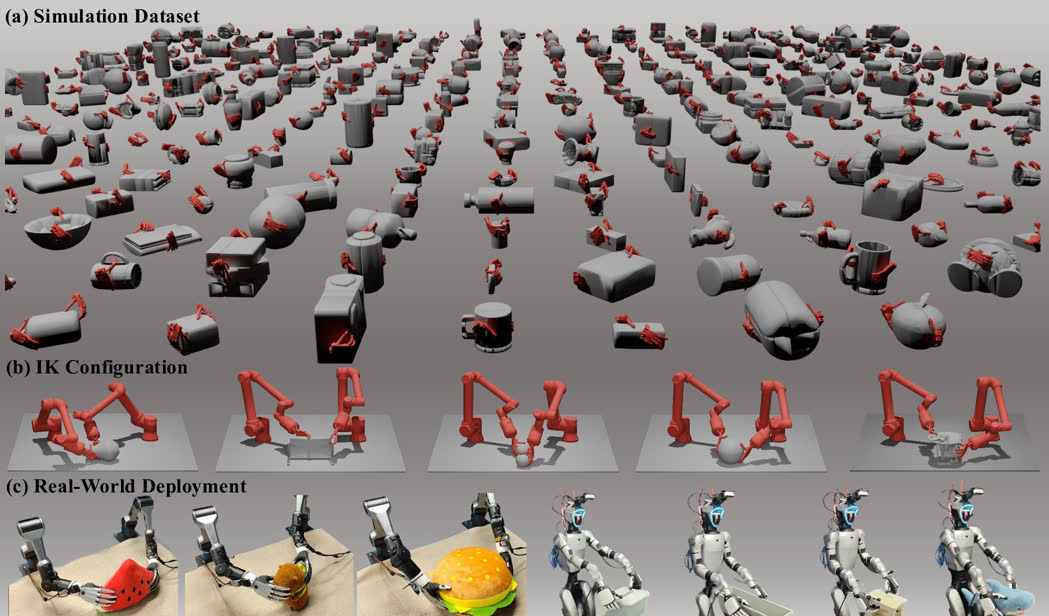
Jiangran Lyu*, Kai Liu*, Xuheng Zhang*, Haoran Liao, Yusen Feng, Wenxuan Zhu, Tingrui Shen, Jiayi Chen, Jiazhao Zhang, Yifei Dong, Wenbo Cui, Senmao Qi, Shuo Wang, Yixin Zheng, Mi Yan, Xuesong Shi, Haoran Li, Dongbin Zhao, Ming-Yu Liu, Zhizheng Zhang, Li Yi, Yizhou Wang, He Wang Robotics: Science and Systems (RSS), 2026 arXiv / project page / code |
|
Mu Lin*, Yi-Lin Wei*, Jiaxuan Chen, Yuhao Lin, Shuoyu Chen, Jiangran Lyu, Jiayi Chen, Yansong Tang, He Wang, Wei-Shi Zheng✉ Conference on Robot Learning (CoRL), 2026 Spotlight arXiv / project page |
|
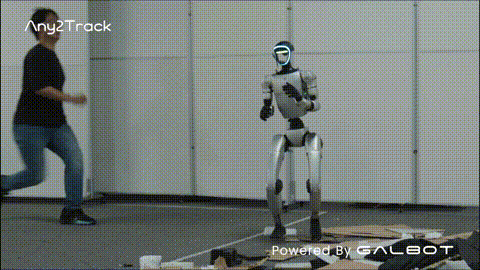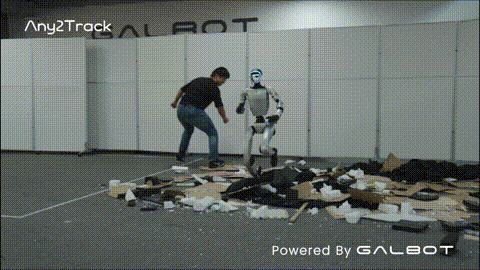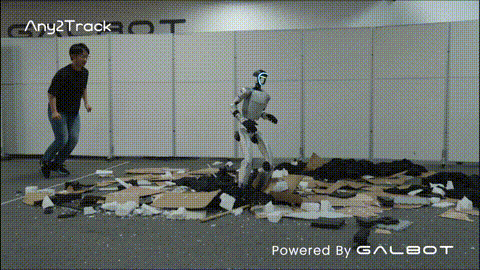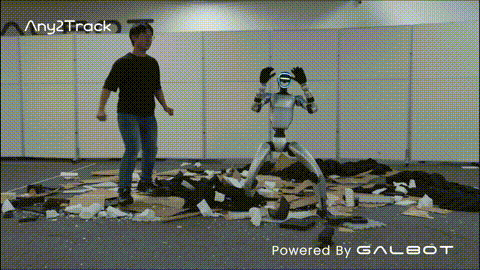
Zhikai Zhang*, Jun Guo*, Chao Chen, Jilong Wang, Chenghuai Lin, Yunrui Lian, Han Xue, Zhenrong Wang, Maoqi Liu, Jiangran Lyu, Huaping Liu, He Wang, Li Yi International Conference on Robotics and Automation (ICRA), 2026 arXiv / project page / code (OpenTrack) We present Any2Track, a foundational humanoid motion tracker to track any motions under any disturbances. |
|
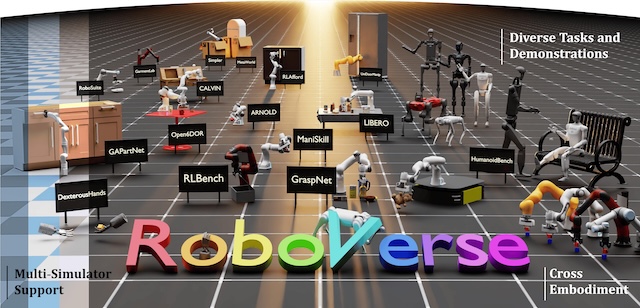
Haoran Geng, Feishi Wang, Songlin Wei, Yuyang Li, Bangjun Wang, Boshi An, Charlie Cheng, Haozhe Lou, Peihao Li, Yen-Jen Wang, Yutong Liang, Dylan Goetting, Chaoyi Xu, Haozhe Chen, Yuxi Qian, Yiran Geng, Jiageng Mao, Weikang Wan, Mingtong Zhang, Jiangran Lyu, Siheng Zhao, Jiazhao Zhang, Jialiang Zhang, Chengyang Zhao, Haoran Lu, Yufei Ding, Ran Gong, Yuran Wang, Yuxuan Kuang, Ruihai Wu, Baoxiong Jia, Carlo Sferrazza, Hao Dong, Siyuan Huang, Koushil Sreenath, Yue Wang, Jitendra Malik, Pieter Abbeel Robotics: Science and Systems (RSS), 2025 arXiv / project page / document / code |
|
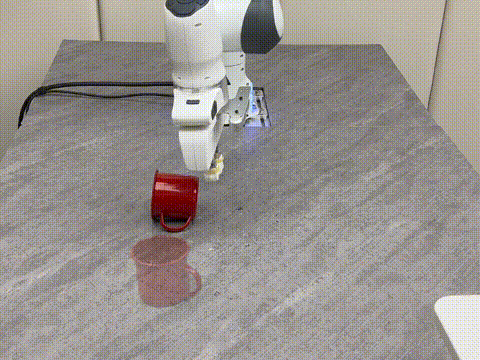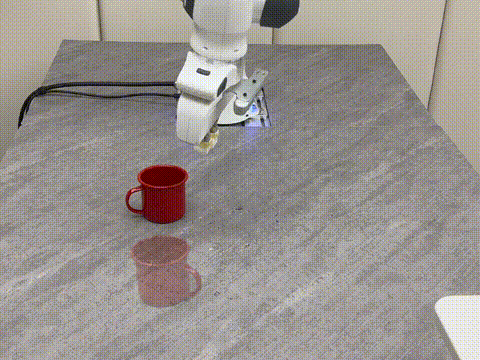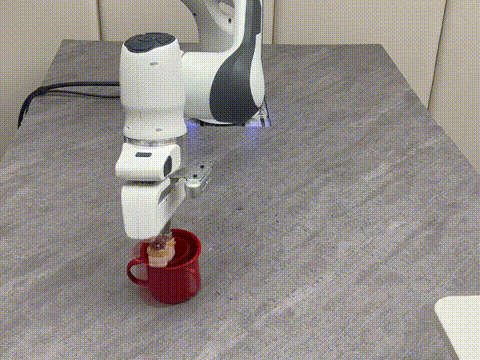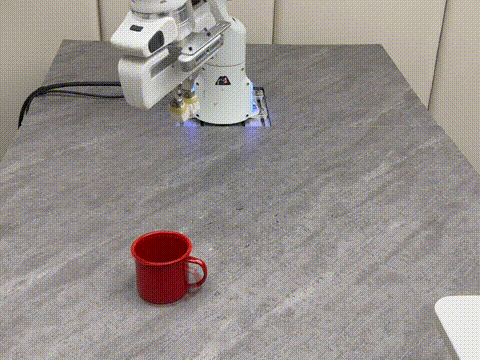
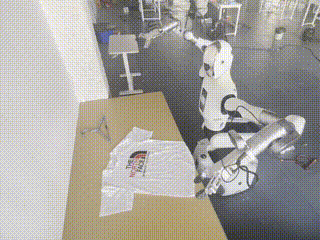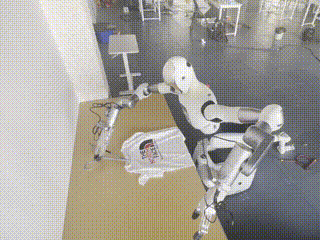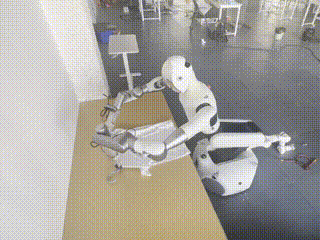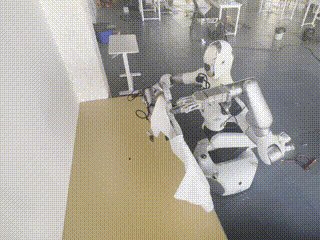
Jiangran Lyu, Ziming Li, Xuesong Shi, Chaoyi Xu, Yizhou Wang✉, He Wang✉ International Conference on Computer Vision (ICCV) 2025 🌍 First-ever World Action Model arXiv / project page / code DyWA is the first work to introduce the World Action Model, jointly predicting future states for action learning while adapting to dynamics variations from historical trajectories. |
|
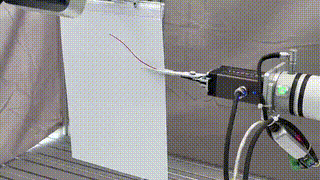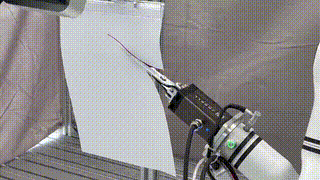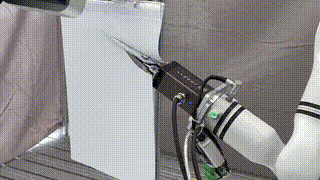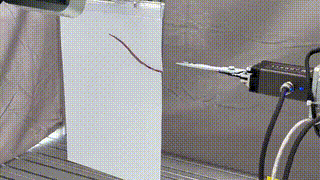
Yuxing Chen, Songlin Wei, Bowen Xiao, Jiangran Lyu, Jiayi Chen, Feng Zhu, He Wang✉ IEEE Robotics and Automation Letters (RAL) 2025 arXiv / project page This work explores robotic hanger insertion with a focus on diverse garments, leveraging a novel learning-based approach. |
|
Jiangran Lyu, Yuxing Chen, Tao Du, Feng Zhu, Huiquan Liu, Yizhou Wang✉, He Wang✉ Conference on Robot Learning (CoRL), 2024 Data Generation for Robotics@RSS, 2024 arXiv / project page / code We propose the first learning-based robotic paper cutting system. Experimental results demonstrate that our method achives performance comparable to human operation with a single hand under the same conditions. |
|
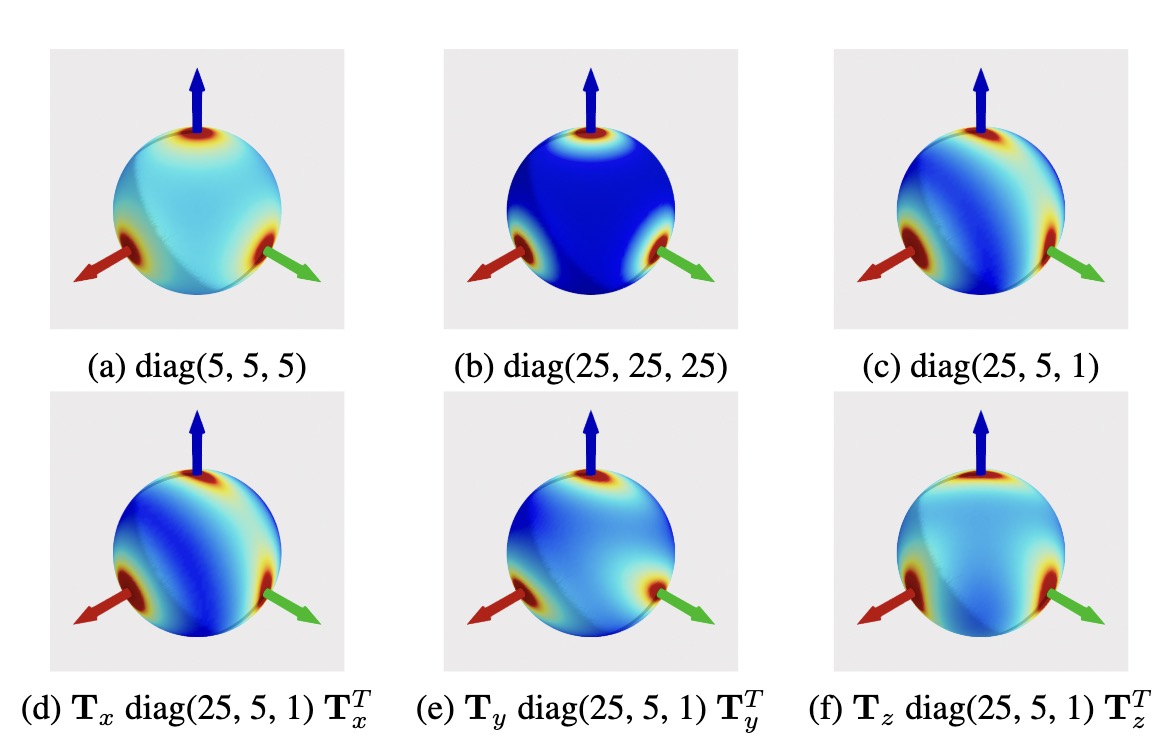
Yingda Yin*, Jiangran Lyu*, Yang Wang, Haoran Liu, He Wang✉, Baoquan Chen✉, IEEE Transactions on Pattern Analysis and Machine Intelligence (TPAMI), 2025 arXiv / project page / code We propose a novel Rotation Laplace distribution for probabilistic rotation estimation. Rotation Laplace distribution is robust to the disturbance of outliers and enforces much gradient to the low-error region, resulting in new state-of-the-art performance over both probabilistic and non-probabilistic baselines. |
|
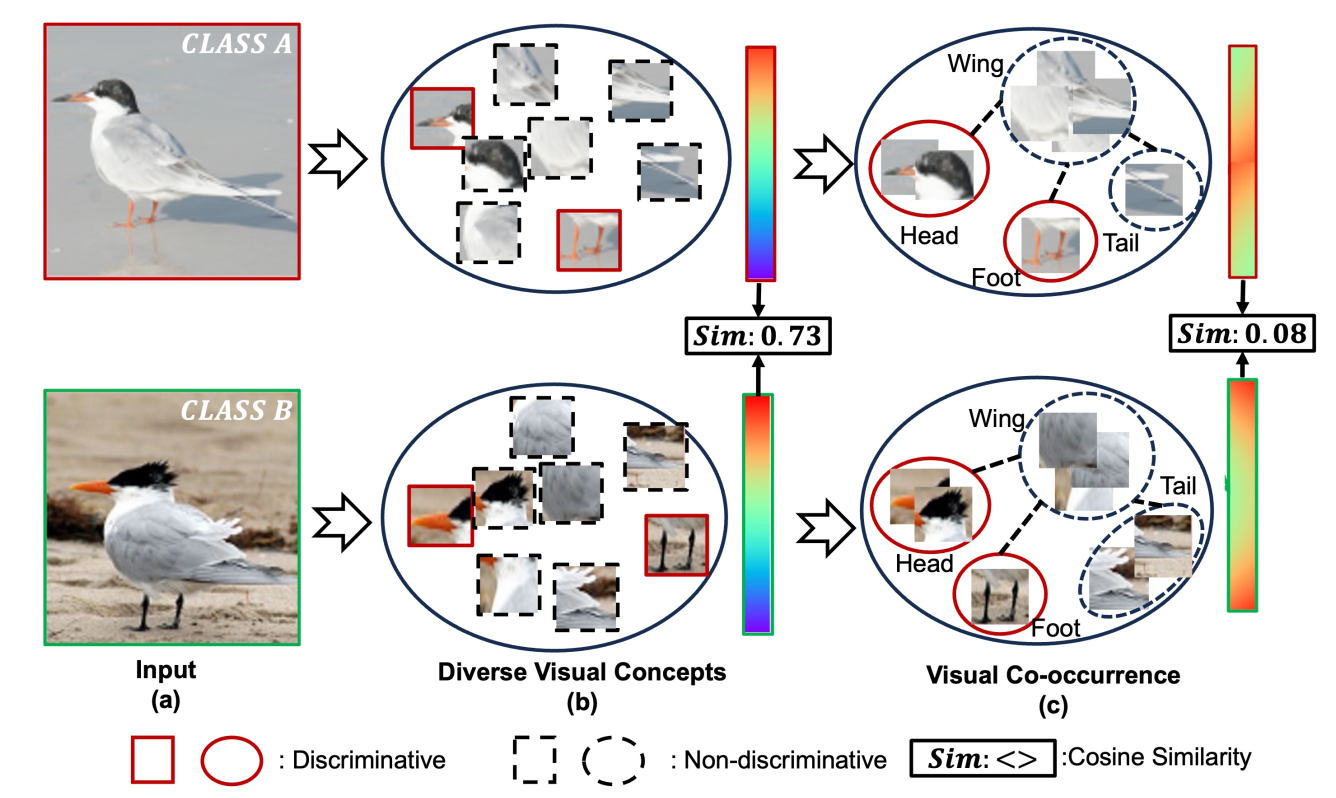
Shijie Wang, Haojie Li✉, Jiangran Lyu, Qi Tian, IEEE Transactions on Pattern Analysis and Machine Intelligence (TPAMI), Under Review arXiv / project page / code We propose a novel Visual Co-occurrence Discovery Network (VCDN) to discover semantic co-occurring relationships within objects and facilitate the inference of their compositional structures. |
|
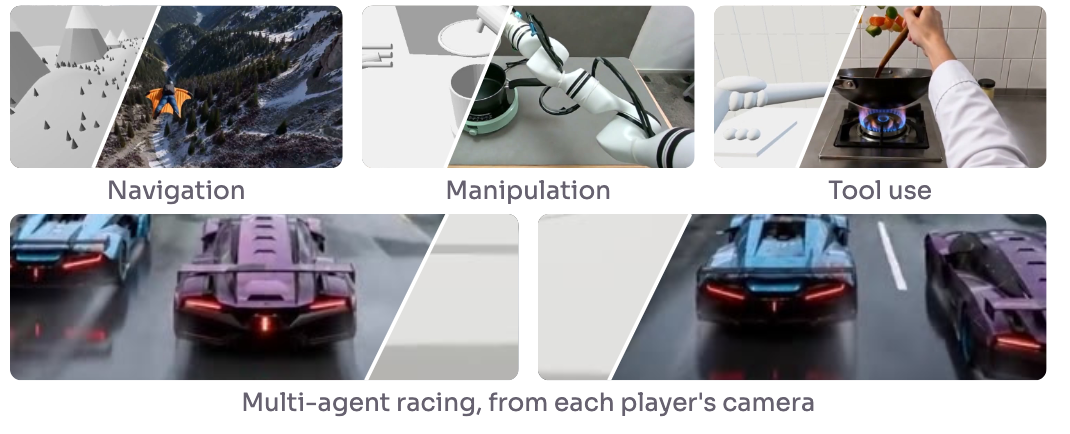
MirroS Team MirroS Technical Report, 2026 arXiv / project page / code / blog |
|
|
|
Building Physical RSI 2026.7 - Present |
 |
Collaborated Scientist at Cosmos Lab Collaborator: Dr. Ming-Yu Liu 2025 - Present |
|
Research Scientist 2023.5 - 2026.7 |
 |
Ph.D. student in Computer Science Advisor: Prof. Yizhou Wang and Prof. He Wang 2023.9 - Present |
|
|
Website template courtesy of Jon Barron. |